What’s the difference between CAN bus and automotive Ethernet? CAN is a shared, arbitration-based network for compact control messages, while automotive Ethernet usually uses point-to-point links and switches for far more bandwidth and IP-based traffic. CAN FD remains part of the CAN family, and modern vehicles commonly connect CAN and Ethernet through gateways.
CAN and automotive Ethernet solve different in-vehicle networking problems. CAN prioritizes economical, robust distributed control; automotive Ethernet prioritizes bandwidth, switching, IP-based communication, and data-heavy vehicle architectures. The right choice depends on traffic volume, latency, topology, existing electronics, diagnostics, safety design, and whether the vehicle needs a gateway between network domains.
As an Amazon Associate I earn from qualifying purchases.
Key takeaways
- CAN is a shared, multi-node control bus whose message identifiers determine priority when nodes contend for access.
- Automotive Ethernet usually uses point-to-point links and switches, giving it a much higher-bandwidth path for cameras, ADAS, infotainment, diagnostics, and central computing.
- CAN FD remains CAN: its data field can reach 64 bytes, but CAN FD does not become IP Ethernet or acquire Ethernet switching behavior.
- According to the IEEE Standards Association’s 2026 automotive networking overview, automotive single-pair Ethernet families include 10 Mb/s, 100 Mb/s, 1 Gb/s, and higher rates.
- CAN and automotive Ethernet are complementary in most vehicles, with gateways connecting low-bandwidth CAN segments to high-bandwidth Ethernet domains.
What is the difference between CAN bus and automotive Ethernet?
The fundamental difference is network architecture. CAN is a shared differential bus: multiple electronic control units use the same physical network and resolve simultaneous transmissions through priority arbitration. Automotive Ethernet usually uses separate point-to-point links joined by switches, so it can move substantially more data and support IP-based communication.
Recommended Free Tools
| Comparison | CAN and CAN FD | Automotive Ethernet |
|---|---|---|
| Basic network model | Shared multi-node bus with distributed message arbitration | Usually point-to-point links connected by Ethernet switches |
| Typical physical arrangement | Differential two-wire bus with termination, cable-topology, and stub constraints | Automotive single-pair PHY links, switches, and gateways; star, tree, and zonal layouts are common architectural options |
| Bandwidth | Classical CAN is commonly associated with rates up to 1 Mbit/s; CAN FD can use a faster data phase, depending on the design | Automotive PHY families include 10 Mb/s, 100 Mb/s, 1 Gb/s, and higher rates |
| Payload model | CAN FD data fields can contain up to 64 bytes | Ethernet frames carry substantially larger payloads and can transport IP protocols, subject to the selected stack and MTU |
| Medium access | Priority-based arbitration; the lower numerical identifier wins when messages compete under CAN’s dominant and recessive bit rules | Link transmission and switch forwarding; timing depends on traffic, buffering, switch configuration, scheduling, and synchronization |
| Typical strengths | Robust distributed control, compact messages, mature tools, economical nodes, and priority-based access | Cameras, ADAS, infotainment, diagnostics, software transfer, central compute, zonal backbones, and IP-based services |
| Main design concerns | Bus loading, bit timing, termination, cable topology, error states, and identifier priority | PHY compatibility, switch design, EMI, link budget, traffic scheduling, synchronization, cybersecurity, and higher-layer protocols |
The practical question is therefore not usually which technology replaces the other. Vehicle engineers assign compact control traffic to CAN or CAN FD, high-volume data and backbone traffic to automotive Ethernet, and use gateways where the two domains must exchange information.
#1 Best Overall

- CAN Mode: Automatic regonize the direction of CAN-H and CAN-L, can read CAN BUS Baud Range: 50, 83, 100,125,150,200,250,300,400,500,666,800,1000kbps
- LIN Mode: can read LIN BUS Baud Range: 2400-4800-9600-14400-19200bps. Red plug connects to LIN, black plug connects to GND.
- PWM Singal Mode: < 20V PWM singal detector for line.
- View Standard Frames ID data: Easy to stop the ID page to read the part of standard frames data.
- Directly use CAN/LIN/PWM analyzer quickly check if the plug with communication data or not.
How does CAN bus work?
CAN is a message-oriented network in which multiple nodes share one bus. A node waits for an idle bus and begins transmitting a frame. If two or more nodes start at the same time, the nodes compare transmitted and observed bus bits during arbitration. A dominant bit overrides a recessive bit, so the message with the higher CAN priority continues while losing nodes stop transmitting and retry later.
CAN priority is encoded in the message identifier rather than assigned by a central scheduler. Under the normal identifier rules, a lower numerical identifier has higher priority. That arrangement lets an urgent control message win access without destroying the losing frame or requiring a collision-recovery exchange.
CAN’s control-oriented design also includes substantial error handling. CAN controllers can detect bit, stuff, CRC, form, and acknowledgment errors. Transmit and receive error counters help a controller move between error-active and error-passive behavior, while a persistently faulty node can enter a bus-off state. Those mechanisms support fault confinement, but they do not compensate for poor termination, incorrect bit timing, bad grounding, electromagnetic interference, or damaged wiring.
The shared-bus model keeps the node hardware and communication pattern compact, but the entire bus is a physical timing problem. Cable length, stubs, node count, termination, bus load, transceiver characteristics, and bit rate all affect the reliable operating margin. The AUTOSAR CAN Driver specification documents CAN-family support in an automotive software context, while CAN in Automation’s technical guidance covers the physical and timing considerations that become especially important with CAN FD.
Why is CAN FD not the same as Ethernet?
CAN FD is an enhancement to CAN, not a conversion of CAN into Ethernet. CAN FD keeps CAN’s shared-bus communication model and priority arbitration while allowing a larger data field and a faster data phase.
According to CAN in Automation’s 2025 CAN FD guidance, a CAN FD data field can contain from 0 to 64 bytes. The same cited material describes the nominal CAN FD arbitration phase as limited to 1 Mbit/s. The data-phase rate is not universal: transceiver capability, network topology, cable quality, signal integrity, configuration, and timing margins determine what a particular network can sustain.
CAN FD therefore improves the amount of data carried per frame and can reduce transmission time during its data phase, but CAN FD does not provide Ethernet frames, IP addressing, Ethernet switches, or Ethernet’s point-to-point link behavior. CAN FD is still the right description for a CAN-family network.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
CAN FD physical design deserves more care than a casual description such as CAN FD runs at 8 Mbit/s suggests. CAN in Automation’s CiA 601-series guidance addresses transceiver behavior, bit timing, cabling, signal integrity, low-power operation, and selective wake-up. A CAN FD design should state its actual configured arbitration and data-phase rates rather than implying that every CAN FD network has the same speed.
Rank #2

- 【Basic Introduction】The upgraded OBD2 Breakout Box is a specialized automotive tool designed for OBD diagnostic link connectors. It enables simultaneous connection to multiple diagnostic devices for testing purposes. This tool offers convenient and secure access to the OBDII connector, allowing for the monitoring of protocol signals, power, and grounds.
- 【Powerful Features】This breakout box kit can also power the on-board computer, test OBD voltages, and perform other functions. The OBDII Breakout Box can be easily connected directly to the vehicle's on-board data link, providing straightforward access to the vehicle's data bus line.
- 【16 Pins OBDII Interface】The input jack arrangement of the OBDII diagnostic link connector faithfully replicates the 16-pin configuration of the OBDII interface. This design facilitates rapid and straightforward testing of a wider range of connections, granting you swift access to all 16 pins for efficient vehicle servicing and diagnostics.
- 【Built-In 4mm Input Jacks】The Automotive OBDII Protocol Monitor features built-in input jacks compatible with 4mm banana plugs, facilitating easy connections to multimeters or oscilloscopes for more in-depth measurements. By linking to a DC 8V-30V power source, it can supply power to the vehicle's ECU, making it useful for battery replacements and related tasks.
- 【Flexible Cable & 5ft Battery Alligator Clip】 The OBD II extension cable spans 17.7 inches, Crafted from supple thermoplastic TPU material, which is durable.The 5-foot battery alligator clip cable is tailored for DC2.1*5.5mm connections, perfectly suited for DC12V at 2A power supply.
What is CAN XL?
CAN XL is still a member of the CAN family, although it targets larger payloads and higher data rates than Classical CAN and CAN FD. CAN XL is not automotive Ethernet and does not inherit Ethernet’s switching or IP behavior.
According to the AUTOSAR R23-11 CAN Driver documentation, CAN XL is described with adjustable rates up to 20 Mbit/s and payloads up to 2,048 bytes. Those figures describe the capabilities discussed in that documentation; implementation, vehicle deployment, and current production status should be checked separately before treating CAN XL as a universally available replacement for Ethernet.
How does automotive Ethernet work?
Automotive Ethernet is a collection of Ethernet physical layers, switches, protocol stacks, synchronization methods, and automotive qualification practices rather than one single speed, connector, or wiring standard. The exact PHY matters because speed, topology, duplex behavior, cable requirements, and maximum link characteristics vary between Ethernet families.
Do these 3 things before closing this tab:
1Fix the driver behind crashes, sound loss and screen glitches2Repair Windows errors before they cause bigger problems3Scan for outdated or missing drivers - takes under a minuteIn a typical switched design, each ECU or zone connects to an Ethernet switch through its own link. The switch examines frame information and forwards traffic to another port. A larger network can contain multiple switches, gateways, central computers, zonal controllers, and links running at different rates. AUTOSAR’s Ethernet State Manager specification is one example of the vehicle software infrastructure built around managed automotive Ethernet communication rather than an unmanaged cable alone.
Ethernet frames can carry much larger payloads than CAN frames and can transport IP-based protocols. That makes automotive Ethernet suitable for high-volume sensor data, service-oriented communication, diagnostics, firmware packages, and connections between compute platforms. The nominal link rate still does not equal application throughput: Ethernet headers, higher-layer protocol overhead, switch contention, buffering, traffic scheduling, and the selected MTU all consume capacity or affect latency.
What is 100BASE-T1?
100BASE-T1 is a 100 Mb/s automotive Ethernet physical layer that uses one unshielded twisted pair for a full-duplex point-to-point connection. Texas Instruments describes 100BASE-T1 as a physical full-duplex interface over an unshielded single twisted pair in its 2018 automotive Ethernet technical paper. The technology is also encountered under the historical BroadR-Reach name.
Full duplex means the two connected PHYs transmit and receive simultaneously over the same pair using techniques such as hybrid circuits and echo cancellation. A 100BASE-T1 link is not a shared multi-node CAN bus: two endpoints normally occupy the link, and an Ethernet switch is required when more endpoints must communicate.
Quick wins for a faster PC:
Scan for outdated or missing drivers - takes under a minuteDriver Scan →Repair Windows errors before they cause bigger problemsFix Now →Fix the driver behind crashes, sound loss and screen glitchesFind Drivers →100BASE-T1 should not be used as a synonym for all automotive Ethernet. According to the IEEE Standards Association’s 2026 automotive in-vehicle networking overview, automotive single-pair Ethernet PHY families include 10 Mb/s, 100 Mb/s, 1 Gb/s, and higher-speed variants. The 10BASE-T1S family is an important contrast because it supports 10 Mb/s single-pair Ethernet with multidrop operation, giving it a different physical and access model from 100BASE-T1.
Rank #3

- Latest PRO Edition with faster processing, improved interface, and expanded protocol simulation tools for advanced CAN-BUS diagnostics and training.
- Includes Sniffer to monitor live CAN-BUS data and Trainer to build and send custom OBD2 and J1939 messages. Simulate real vehicle behavior directly from your PC.
- Simulates OBD-II fault codes, J1939 PGNs, CANopen control frames, and marine NMEA 2000 messages. Ideal for automotive, truck, marine, and industrial applications.
- Comes with a printed CAN-BUS training book covering frames, PGNs, PIDs, diagnostics, and network fundamentals. Perfect for students, technicians, and engineers.
- Includes Trainer Kit PRO Edition, PRO software access, USB-C cables, OBD2 to Deutsch adapter, J1939 connector, and Quick Start Guide. Works on most Windows PCs.
Is automotive Ethernet faster than CAN?
Yes, automotive Ethernet is generally much faster than Classical CAN, and Ethernet also offers higher-rate options than CAN FD for data-heavy vehicle functions. The comparison must use the exact Ethernet PHY and CAN configuration, because neither CAN nor automotive Ethernet has one universal speed.
Classical CAN is commonly associated with rates up to 1 Mbit/s, while CAN FD preserves a nominal arbitration phase and may accelerate only its data phase. By contrast, IEEE automotive single-pair Ethernet families span 10 Mb/s, 100 Mb/s, 1 Gb/s, and higher rates. According to Texas Instruments’ 2018 description of 100BASE-T1, 100BASE-T1 operates at 100 Mb/s. Those are link or phase rates, not guaranteed application throughput or response time.
| Traffic requirement | More natural first choice | Reason |
|---|---|---|
| Small control commands and status messages | CAN or CAN FD | Compact frames, distributed nodes, and built-in priority arbitration fit modest control traffic |
| Camera or high-resolution sensor stream | Automotive Ethernet | The required data volume is better suited to switched links with much higher bandwidth |
| Firmware or software transfer | Automotive Ethernet | Larger frames, IP-based protocols, and higher rates can shorten bulk transfers |
| Existing body-control subsystem | CAN or CAN FD | Existing ECUs, diagnostics, wiring, and development tools may already be designed around CAN |
| Mixed low- and high-bandwidth vehicle architecture | CAN plus automotive Ethernet | Each network handles the traffic type for which its topology and protocol are best suited |
Which is better for automotive real-time communication?
Neither network is automatically better for every real-time task. CAN’s priority arbitration can provide analyzable response behavior when message priorities, frame lengths, bus load, and error conditions are bounded. Ethernet can provide bounded behavior when the network is deliberately engineered with suitable switching, traffic shaping, time synchronization, scheduling, redundancy, and Time-Sensitive Networking.
When does CAN offer the clearer timing model?
CAN gives engineers a direct priority mechanism. When several messages contend, the highest-priority message wins arbitration without a destructive collision. A properly configured CAN network can therefore be assessed using message priority, worst-case frame duration, bus utilization, and interference from higher-priority traffic.
CAN is not infinitely deterministic. Heavy bus loading, an incorrectly chosen identifier priority, retransmissions caused by errors, excessive cable delay, or an unbounded message set can increase latency. A CAN network also has one shared medium, so every additional message competes for the same bus time.
How does Ethernet provide predictable timing?
Ordinary best-effort Ethernet should not be called deterministic merely because its nominal bit rate is high. A switch may buffer frames, multiple flows may contend for an output port, and traffic configuration affects the time a message spends in the network.
Automotive Ethernet can be engineered for bounded latency and jitter with traffic shaping, synchronization, scheduled transmission, redundancy, and TSN mechanisms. IEEE’s automotive work identifies IEEE 802.1DG-2025 as an automotive in-vehicle Ethernet TSN profile in its 2026 overview. The practical timing result depends on the selected PHY, switch features, traffic classes, synchronization accuracy, schedules, and fault-management design.
Free tools Windows power users keep installed
One-click scans. No signup required.
Which network is more reliable?
CAN has a particularly mature and visible approach to frame error detection and fault confinement, while automotive Ethernet can combine link and frame checks with switch monitoring, synchronization, redundancy, diagnostics, security, and higher-layer recovery. Neither CAN nor Ethernet is inherently reliable or unreliable without considering the complete physical and software design.
Rank #4
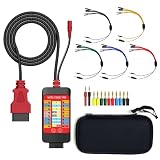
- 【LCD 16-Pin Digital Voltage & Ground Display for All Vehicle with OBD2 Port】WOYO OBD2 DLC breakout box displays true RMS voltage for all 16 OBD-II pins on LCD. Pin 4/5 ground status (OPEN/GND) shown instantly. Flashing green indicates CAN/K-Line activity. Compatible with 12V/24V cars, trucks, motorcycles.
- 【Dual 120Ω CAN Termination for Bench Testing】This ECU testing tool has two independent 120Ω switches for HS-CAN (pins 6&14) and MS-CAN (pins 3&11). Add termination when testing single ECU or small bench networks to reduce signal reflections and ensure stable CAN communication.
- 【Reverse Polarity & Overload Protection】 WOYO DLC breakout box with reverse polarity and current overload protection (up to 2A) guards scan tools, oscilloscopes, and diagnostic computers. Pass-through design maintains low-latency data between scanner and vehicle.
- 【Compact Design with Probe Compatibility】Portable WOYO OBD2 breakout box fits standard 2mm multimeter/oscilloscope probes. Includes 4mm-to-2mm adapters and 10 pin connectors for crocodile-clip leads. Works with most test equipment.
- 【12V/24V Power Port Support Connect Bench Power】This CAN tester box has DC 12V-24V input (5.1×2.2mm) for battery replacement. Also powers ECUs/CAN modules for off-line bench testing.
CAN controllers check bit, stuff, CRC, form, and acknowledgment conditions and maintain transmit and receive error counters. A faulty controller can eventually become bus-off, limiting its ability to disrupt the network. That behavior is valuable for distributed control, but CAN reliability still depends on correct termination, cabling, transceiver selection, grounding, electromagnetic compatibility, and software recovery.
Automotive Ethernet introduces a different set of engineering concerns: PHY compatibility, link budget, connector and cable performance, EMI, switch behavior, traffic scheduling, time synchronization, cybersecurity, and recovery when a link or switch fails. Ethernet’s greater bandwidth does not remove those requirements; it makes the architecture and configuration more important.
Why are automakers moving from CAN to Ethernet?
Automakers are adding Ethernet because vehicles now need to move more data between cameras, radar and other sensors, ADAS processors, displays, infotainment systems, central computers, and zonal controllers. Ethernet also provides a natural foundation for IP-based communication, high-speed diagnostics, software and firmware transfer, and service-oriented vehicle architectures.
The Tool Desk
Outbyte Driver Updater FREEScan for outdated or missing drivers - takes under a minuteDriver Scan →Outbyte PC Repair FREEClear out junk files and repair common Windows errorsFree Scan →The phrase moving from CAN to Ethernet can be misleading. The change is usually an architectural expansion rather than a total replacement. CAN and CAN FD remain economical and practical for many body, chassis, powertrain, sensor, and actuator nodes that exchange compact messages. Ethernet is favored for high-throughput links and backbones. Gateways connect the two so that a low-bandwidth CAN subsystem can exchange selected information with an Ethernet domain.
The choice also reflects existing investment. A vehicle program may already have CAN ECUs, diagnostic procedures, safety analyses, transceivers, harnesses, and service tools. Replacing every CAN segment with Ethernet would not automatically improve a function whose data volume is small. Ethernet is most valuable where bandwidth, switching, IP communication, synchronization, or a zonal architecture solves a genuine system requirement.
Can CAN and Ethernet be used together in a car?
Yes. CAN and automotive Ethernet are commonly used together, with gateways, bridges, or central controllers connecting the two network domains. The gateway may route selected messages, translate between higher-layer representations, manage diagnostics, or pass information between a CAN-family segment and an Ethernet backbone, depending on the vehicle architecture.
CAN and Ethernet do not share the same physical signaling or frame format, so connecting a CAN wire directly to an Ethernet port does not create interoperability. The ECU, gateway, transceiver, switch, and software stack must support the relevant technology. AUTOSAR documentation covers both CAN-family communication and Ethernet-based automotive communication, reflecting the mixed-network reality of vehicle systems.
A mixed architecture lets engineers keep CAN where compact, robust, cost-sensitive control is the priority and use Ethernet where cameras, ADAS, central compute, software updates, diagnostics, or zonal communication demand higher bandwidth. The gateway becomes an important design point because it can introduce latency, filtering rules, data-model translation, and a possible fault boundary.
Best Value

- 【Find OBD2 Connection Problems Faster】 When a scan tool won’t connect or communication becomes unstable, this OBD2 breakout box helps you quickly check the vehicle’s communication, power and ground circuits. Easily narrow down whether the issue may come from the OBD port, vehicle wiring, ECU communication or connected diagnostic equipment—less guesswork, more efficient troubleshooting.
- 【See Power, Ground & Communication at a Glance】 No need to start every diagnosis by probing individual circuits. Color-coded LEDs give you an instant visual check of power, ground and communication activity, while the built-in voltage display lets you verify OBD port voltage in real time. Spot abnormal conditions quickly before moving on to deeper testing.
- 【Go Beyond What a Scan Tool Can Show】 A scan tool tells you when communication fails—this breakout box gives you direct access to all 16 OBDII circuits to investigate why. Check individual connections and monitor circuit activity without repeatedly probing the vehicle’s OBD connector, making electrical and CAN Bus troubleshooting easier and more organized.
- 【Ready for Multimeter & Oscilloscope Testing】 Need more than an LED indication? Standard 4mm banana sockets let you connect a compatible multimeter or oscilloscope for voltage measurement and signal analysis. Move smoothly from a quick visual check to deeper electrical diagnosis without changing your entire test setup.
- 【50.4" Extended Cable – More Room to Work】 Stop working around a breakout box hanging underneath the dashboard. The 128cm / 50.4" extension cable gives you enough reach to move the tester away from the cramped footwell and place it where the display and LEDs are easier to see—especially useful when working with additional diagnostic equipment.
Where does each technology fit in a vehicle?
| Vehicle area or function | Likely network fit | Why |
|---|---|---|
| Body-control modules and low-bandwidth actuators | CAN or CAN FD | Compact messages, economical nodes, established diagnostics, and distributed control are usually sufficient |
| Powertrain and chassis control | CAN, CAN FD, or a mixed architecture | Priority-based control traffic and mature embedded implementations remain useful, while higher-level systems may connect through Ethernet |
| Distributed modest-data sensors | CAN or CAN FD | CAN handles periodic status and command messages without requiring a high-bandwidth backbone |
| Cameras and ADAS sensor data | Automotive Ethernet | High-volume data benefits from faster PHYs, switching, and larger Ethernet payloads |
| Infotainment, displays, and audio/video transport | Automotive Ethernet | Ethernet provides a higher-bandwidth, IP-capable network for data-rich services |
| Central compute and zonal backbones | Automotive Ethernet | Switched links and higher-rate PHYs support aggregation between zones and compute platforms |
| Legacy subsystem connected to a modern backbone | CAN plus an Ethernet gateway | The gateway allows the existing CAN network and the Ethernet domain to exchange selected information |
Do you need a CAN analyzer or an OBD2 scanner?
The correct tool depends on whether you need to inspect raw network traffic or perform vehicle-level diagnostics. A CAN analyzer observes and works with CAN frames; an OBD2 scanner generally communicates with supported diagnostic services through the vehicle’s diagnostic connector. An OBD2 scanner is not automatically a general CAN analyzer and does not automatically test automotive Ethernet.
| Tool type | Best use | What it can help reveal | What it does not guarantee |
|---|---|---|---|
| CAN bus analyzer | CAN or CAN FD development, troubleshooting, and raw bus inspection | Frames, identifiers, payloads, timing, bus activity, and protocol behavior supported by the tool | Automotive Ethernet traffic analysis or plug-and-play access to every vehicle network |
| OBD2 CAN diagnostic scanner | Service diagnostics through a compatible OBD2 connection | Supported diagnostic trouble codes, live data, and vehicle functions exposed through the scanner’s protocols | Arbitrary CAN frames, proprietary messages, every ECU, or an automotive Ethernet link |
| Automotive Ethernet test equipment | PHY, link, switch, traffic, timing, and Ethernet-network validation | Ethernet link state, traffic behavior, PHY and switch operation, and selected higher-layer protocols | CAN frames unless the equipment also includes a CAN interface or gateway function |
| CAN-to-Ethernet interface or gateway | Connecting or exchanging data between CAN-family and Ethernet systems | Traffic selected and translated or routed by the specific interface and its software | Universal protocol decoding, compatibility with every vehicle, or automatic access to proprietary data |
If you are experimenting with CAN traffic or diagnosing a development network, a CAN bus analyzer or USB-to-CAN FD interface is the relevant type of tool. Microchip’s CAN Bus Analyzer FD user guide documents the dedicated analyzer category for automotive and other CAN applications. Marketplace product documentation also uses terms such as USB-to-CAN FD interface converter and CAN protocol data analyzer, but product compatibility, software support, and vehicle access must be verified before purchase.
An OBD2 CAN diagnostic scanner is more appropriate when the goal is to read supported diagnostic trouble codes or live data from a vehicle through its diagnostic interface. An OBD2 scanner may use ISO 15765-4 CAN, as shown by marketplace examples, but the scanner’s diagnostic functions do not make it a raw bus monitor. The scanner may not expose proprietary frames, let you transmit arbitrary messages, decode manufacturer-specific signals, or inspect an Ethernet backbone.
For a laboratory that works across both technologies, specialist equipment can include professional CAN/CAN FD interfaces, CAN-to-Ethernet gateways, automotive Ethernet PHY evaluation boards, switch evaluation kits, and network-analysis software. CSS Electronics documents a CAN interface with USB and Ethernet connectivity, illustrating why a bridge-oriented tool category can be useful when a project spans CAN and Ethernet. A device’s actual supported protocols and analysis functions still need to be checked individually.
How should you choose between CAN, CAN FD, and automotive Ethernet?
- Start with the data requirement. Use CAN when the function exchanges compact commands, status values, or actuator messages. Consider CAN FD when larger payloads or a faster data phase would help without changing the CAN-family architecture. Use automotive Ethernet when cameras, ADAS, bulk software transfer, central compute, or other high-volume traffic exceeds the practical CAN budget.
- Define the timing requirement. For priority-driven control with bounded traffic, CAN arbitration can be straightforward to analyze. For Ethernet, specify the switch behavior, traffic classes, shaping, synchronization, schedules, and TSN features required to achieve bounded latency and jitter.
- Choose the physical topology. CAN requires careful shared-bus wiring, termination, bit timing, and stub control. Automotive Ethernet normally uses point-to-point links and switches, but the exact PHY determines whether the network is full duplex, multidrop, 10 Mb/s, 100 Mb/s, 1 Gb/s, or another configuration.
- Account for the existing vehicle ecosystem. Existing ECUs, transceivers, diagnostics, service tools, software stacks, safety cases, and gateway behavior can make CAN or CAN FD the more practical choice even when Ethernet is available.
- Evaluate the complete system, not the headline bit rate. Compare ECU and transceiver cost, switch and gateway requirements, cable and connector constraints, EMI, signal integrity, fault confinement, cybersecurity, update requirements, development tools, and service procedures.
- Use both when the requirements are mixed. A CAN segment for distributed control plus an Ethernet backbone for high-volume traffic is often more appropriate than forcing every function onto one network.
Bottom line
CAN is a shared, priority-arbitrated control network; automotive Ethernet is usually a switched, point-to-point network built for much higher bandwidth and IP-based communication. CAN FD improves CAN without becoming Ethernet. For most modern vehicles, the technically sound answer is not CAN versus Ethernet but CAN and Ethernet connected by carefully designed gateways.
Frequently Asked Questions
Is automotive Ethernet faster than CAN?
Yes. Automotive Ethernet is generally much faster than Classical CAN, but the exact comparison depends on the CAN or CAN FD configuration and the Ethernet PHY. Automotive Ethernet families include 10 Mb/s, 100 Mb/s, 1 Gb/s, and higher rates, while Classical CAN is commonly associated with rates up to 1 Mbit/s.
Is CAN FD the same as Ethernet?
No. CAN FD is an enhanced member of the CAN family. CAN FD supports data fields up to 64 bytes and can use a faster data phase, but it does not use Ethernet frames, IP communication, Ethernet switches, or Ethernet’s point-to-point link model.
PC Slower Than It Used to Be?
A free scan shows the junk files, broken settings and background clutter dragging Windows down - then fixes them in one click.Free scan · Windows 10 & 11Crashes, No Sound, or Screen Glitches?
Random freezes, missing sound and display glitches usually trace back to one bad driver. Find and replace yours safely.Free scan · under a minuteCan an OBD2 scanner test automotive Ethernet?
Usually no. An OBD2 scanner reads supported vehicle diagnostic services such as trouble codes and live data, while a CAN analyzer is intended to inspect CAN or CAN FD traffic. An OBD2 scanner does not automatically expose proprietary CAN frames or test an automotive Ethernet backbone.
What is 100BASE-T1?
100BASE-T1 is a 100 Mb/s automotive Ethernet physical layer that uses one unshielded twisted pair for a full-duplex point-to-point link. Connecting multiple endpoints normally requires an automotive Ethernet switch; 100BASE-T1 is not a shared CAN bus.
The Bottom Line
Bottom line: CAN remains a strong choice for compact, robust, cost-sensitive control traffic. Automotive Ethernet is the better fit for cameras, ADAS, central compute, zonal backbones, diagnostics, and software transfer. CAN FD is still CAN, and a mixed CAN-plus-Ethernet architecture is usually the practical vehicle design.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.




