Recommended Free Tools
There is no defensible universal answer to “Which ADAS SoC is fastest?” from TOPS figures alone. A useful comparison needs the same workload on each device, measured 99.9th-percentile latency, accuracy, sustained behavior and official measured system power—along with enough software, input and hardware detail for someone else to reproduce the result. MLPerf Automotive offers a common reference, but its proof of concept is not a final production ranking.
What makes an ADAS SoC benchmark meaningful?
An ADAS chip has to process the vehicle’s actual workloads within real-time constraints. A peak arithmetic figure cannot show whether a particular model meets its deadline under sustained sensor load, maintains its target accuracy or does so within an acceptable power envelope.
As an Amazon Associate I earn from qualifying purchases.
MLPerf Automotive identifies latency as its main KPI because automotive systems are real-time and often functionally safe. For its defined stream scenarios, the reported performance metric is measured 99.9th-percentile latency. That tail value helps reveal deadline-risking slow runs that an average can conceal.
The v0.5 suite defines three workloads: 2D object detection with SSD, 2D semantic segmentation with DeepLabV3+, and 3D object detection with BEVFormer-tiny, using Cognata and nuScenes data. MLPerf Automotive’s documentation describes the scenarios and workload table; those definitions matter because a result applies to the tested model, data and scenario, not automatically to every ADAS task.
#1 Best Overall

- 【HIGH PERFORMANCE 2MP IMAGING】Featuring a 2MP automotive-grade CMOS image sensor with 1920x1080 resolution at 30fps, delivering clear and stable image quality for demanding machine vision applications
- 【GMSL2 SERIALIZATION INTERFACE】Equipped with MAX96717F serializer supporting GMSL2 communication protocol, enabling high-speed data transmission over a single coaxial cable for reliable long-distance signal integrity
- 【PROFESSIONAL OPTICAL SYSTEM】AA lens with precise factory calibration and glue-secured focus, available in 195 ultra-wide or 118.4 wide field of view options to suit various surround-view and blind-spot monitoring scenarios
- 【INDUSTRIAL GRADE DURABILITY】IP67-rated waterproof housing protects against dust and water ingress, with operating temperature range from -40C to 85C for reliable performance in harsh environments
- 【BUILT IN IMAGE PROCESSING】Integrated ISP with HDR support and LED flicker mitigation ensures superior image quality in challenging lighting conditions, while 9-12V PoC power supply simplifies system integration
Why TOPS does not answer “Which chip is faster?”
TOPS is a vendor-supplied peak arithmetic figure. It is background about a claimed compute capability, not a measurement of end-to-end task speed, model quality or sustained performance. Different devices may use different architectures, precision modes, software stacks, memory systems and workload assumptions, so placing their peak TOPS figures side by side does not create a like-for-like benchmark.
Nor does TOPS alone determine how much compute an L2 or L3 system needs. The required capability depends on the functions, models, sensor streams, concurrency and system design. The material published here establishes no universal TOPS threshold for either driving level; a buyer should specify workloads and timing requirements rather than select a chip against an unsupported threshold.
What the public vendor figures do—and do not—show
| Platform or family | Published information | What the figure supports | What it cannot establish |
|---|---|---|---|
| NVIDIA DRIVE AGX Orin SoC | Up to 254 TOPS, according to NVIDIA’s current safety report. | A vendor-stated peak figure for the Orin SoC. | Task latency, accuracy, sustained throughput or measured system power on a shared workload. |
| NVIDIA DRIVE AGX platform family | Up to 2,000 TOPS on NVIDIA’s broader DRIVE AGX page. | A figure for the platform family’s advertised configuration. | A value to attribute to one Orin SoC; the platform-family figure and single-SoC figure describe different scopes. |
| Qualcomm Snapdragon Ride | In 2021, Qualcomm reported a range from 10 TOPS in a sub-5 W windshield-mount ADAS camera platform to more than 700 TOPS for fully automated-driving solutions. | The range of products and power envelopes Qualcomm described at that time. | A same-device comparison: the figures span different products and power envelopes, and are not workload benchmark results. |
| Mobileye EyeQ family | Mobileye describes proprietary accelerators optimized for computer vision, signal processing and machine learning, with designs intended for ASIL-D automotive applications. | Mobileye’s description of its accelerator focus and design intent. | A direct, independently validated speed or efficiency ranking against another vendor. |
| Mobileye EyeQ6H versus Jetson AGX Orin | Mobileye publishes a direct comparison page with single-stream latency and power-oriented fields. | A vendor-published comparison whose disclosed scope can be inspected. | A universal independent ranking across workloads, configurations or production vehicles. |
These figures answer different questions. NVIDIA’s 254 TOPS claim is for a single Orin SoC, while the 2,000 TOPS claim concerns the broader DRIVE AGX platform family. Qualcomm’s 2021 range spans a low-power camera platform and higher-end automated-driving solutions. Neither range should be read as a contest between equivalent devices. Mobileye’s EyeQ6H-versus-Orin page is more directly comparative, but remains a vendor-published comparison: its conclusions should be limited to the disclosed setup and measurements.
Do these 3 things before closing this tab:
1Repair Windows errors before they cause bigger problems2Fix the driver behind crashes, sound loss and screen glitches3Clear out junk files and repair common Windows errorsWhat to measure in a fair comparison
- Real-time performance: measured 99.9th-percentile task latency under a representative stream load, not just average latency.
- Quality at that performance: model accuracy against the benchmark target, so an apparent speedup is not achieved by silently reducing quality.
- Sustained behavior: performance at a constant input rate, not only a brief run or single inference.
- Efficiency: official measured system power under the benchmark method. MLCommons policy says official measured system power is the only sanctioned power metric for MLPerf comparisons; TDP, power-supply rating and other proxies are not substitutes.
- Integration scope: the CPU, GPU or NPU, ISP, memory, sensor I/O, virtualization and software toolchain included in the device or platform.
- Safety and maturity: the exact device’s safety evidence and claim, production status, and whether testing used a hardened ECU, development system or engineering sample.
- Workload fit: whether the target is camera-only perception, lidar/radar fusion, driver monitoring, parking, or cockpit and ADAS workloads running concurrently.
How to make results reproducible
- Freeze the workload. Publish the model and version, dataset, input resolution, precision, batch size, preprocessing, postprocessing and sensor count. State the benchmark target and data split so results can be compared on the same basis.
- Define the stream scenario. Report single-stream latency and constant-rate sustained behavior separately. State the offered input rate and publish the measured 99.9th-percentile latency for the defined scenario, rather than reporting only a mean.
- Measure the complete test system. Use the benchmark’s sanctioned system-power method and identify whether the result covers an ECU, evaluation board or engineering sample. Do not substitute a component rating or power-supply limit for measured power.
- Keep quality visible. Report accuracy against the benchmark target beside latency and throughput. A faster result is not comparable if it came from a lower-quality model or changed evaluation conditions.
- Record the software and operating conditions. Include software stack, drivers, compiler, thermal state, clock policy and accelerator partitioning. These details can affect measured outcomes and are needed to reproduce them.
- Separate performance from safety evidence. State the device-specific safety case and the hardware under test independently of benchmark results. ISO 26262-5:2018 covers hardware-level safety-related product development; it explicitly does not address nominal E/E-system performance.
Does MLPerf Automotive prove a chip works in a real car?
No single benchmark result proves that an ADAS SoC works safely in every vehicle or production configuration. MLPerf Automotive provides defined workloads and scenarios for a common comparison point. MLCommons and the Autonomous Vehicle Computing Consortium describe their proof of concept as a community-driven benchmark for OEM and supplier RFIs and RFQs, while explicitly noting that the POC is not performance-optimized. It is therefore useful as a shared reference, not as a final production ranking or vehicle-level validation.
Rank #2
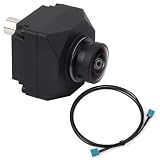
- Automotive-grade sensor & GMSL2 – Based on ISX031 CMOS, with MAX96717 serializer for stable, reliable image capture.
- 120 dB HDR – Clear imaging under strong sunlight and high-contrast scenes.
- Low-noise performance – High-quality images in low light and at night.
- All-glass optics – Multi-element aspherical lenses reduce distortion for sharp images.
- IP-rated & smart processing – Waterproof housing, built-in ISP for noise reduction & color calibration, ideal for ADAS and autonomous systems.
A benchmark run measures the stated test setup and workload. It does not replace integration and validation in the intended vehicle, nor does a strong latency result establish functional-safety compliance. ISO 26262-5:2018’s scope is hardware-level safety-related development, and the standard says it “does not address the nominal performance of E/E systems.” Performance and safety are related engineering concerns, but one is not evidence of the other.
How to decide between Orin, Snapdragon Ride and EyeQ
First specify the functions and concurrent sensor streams the vehicle needs, then set workload-level latency and quality targets and a power envelope. Ask each supplier for results using the same model, input conditions and metric definitions—or run a common benchmark on the candidate systems. Compare measured system power, sustained behavior and test-system scope alongside latency.
Then evaluate integration and readiness: sensor interfaces, compute partitioning, software and compiler support, and the specific safety evidence and production status of the device being offered. Orin’s published peak TOPS, Qualcomm’s broad 2021 Ride range and Mobileye’s EyeQ accelerator description are useful context, but they do not establish a cross-vendor winner on their own. Mobileye’s EyeQ6H-versus-Jetson AGX Orin comparison can inform a narrower comparison only to the extent that its disclosed workload and measurement conditions match the intended use.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.




